
[ad_1]
Robots have trouble improvising and encountering an unusual surface or obstacle usually means an abrupt stop or hard fall. But researchers at Facebook AI have created a new robot locomotion model that adapts in real time to whatever terrain it encounters, altering its gait to keep moving when it hits sand, rocks, stairs and other sudden changes.
While robot movements can be versatile and exact, and robots can “learn” to climb stairs, cross broken ground, and so on, these behaviors are more like individually trained skills that the robot switches between. And while robots like Spot can famously bounce back from being pushed or kicked, the system really only works to correct a physical abnormality while following an unchanged policy of walking. There are some adaptive motion models, but some are very specific (e.g. these based on real insect movements) and others last long enough to work that the robot will definitely have fallen by the time they take effect.
Rapid Motor Adaptation, as the team calls it, grew out of the idea that humans and other animals are able to quickly, effectively and unconsciously adapt their gait to different conditions.
“Suppose you learn to walk and go to the beach for the first time. Your foot sinks in and to pull it out you need to apply more force. It feels strange, but in a few steps you walk just like on hard ground. What’s the secret there?” asked senior researcher Jitendra Malik, who is affiliated with Facebook AI and UC Berkeley.
Especially if you’ve never come across a beach, but even later in life if you have, you don’t go into a special “sand mode” that allows you to walk on soft surfaces. The way you change your movement happens automatically and without any real understanding of the external environment.
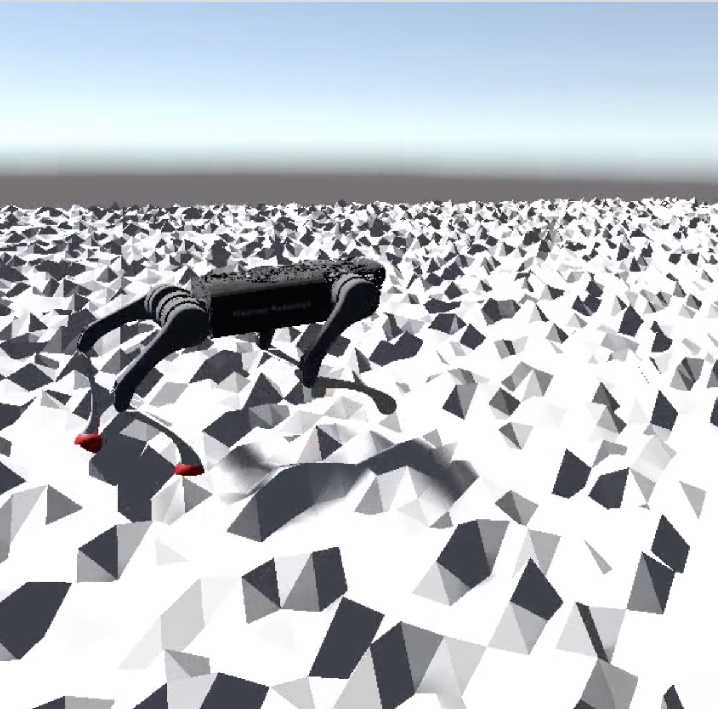
Visualization of the simulation environment. Of course, the robot would not perceive this visually. Image credit: Berkeley AI Research, Facebook AI Research and CMU
“What happens is that your body responds to the different physical conditions by feeling the different effects of those conditions on the body itself,” Malik explained, and the RMA system works in a similar way. “When we walk in new conditions, in a very short time, half a second or less, we have taken enough measurements to estimate what these conditions are, and we adjust the walking policy.”
The system is fully simulation trained, in a virtual version of the real world where the little brain of the robot (everything runs locally on the built-in limited computing unit) learned to maximize forward motion with minimal energy and prevent them from falling by immediately observe and act on data coming in through the joints (virtual), accelerometers and other physical sensors.
To accentuate the overall internality of the RMA approach, Malik notes that the robot does not use any visual input. But sightless people and animals can walk just fine, so why not a robot? But since it’s impossible to estimate the ‘external effects’, such as the exact coefficient of friction of the sand or rocks it walks on, it just keeps a close eye on itself.
“We don’t learn about sand, we learn about the sinking of feet,” said study co-author Ashish Kumar, also of Berkeley.
Ultimately, the system consists of two parts: a main algorithm that is always active and controls the robot’s gait, and a parallel adaptive algorithm that monitors changes in the robot’s internal measurements. When significant changes are detected, it analyzes them the legs should do this, but they do this, meaning the situation is like this and tells the master model how to adapt itself. From then on, the robot only thinks in terms of how to proceed under these new conditions, effectively improvising a specialized gait.
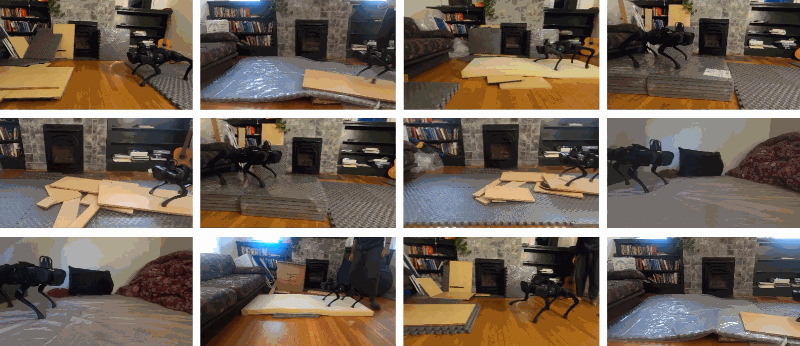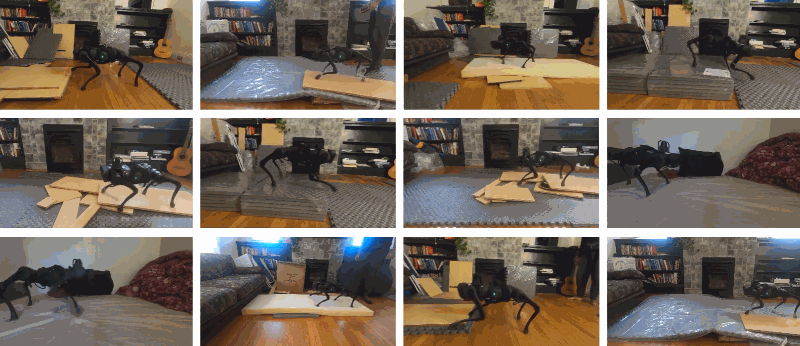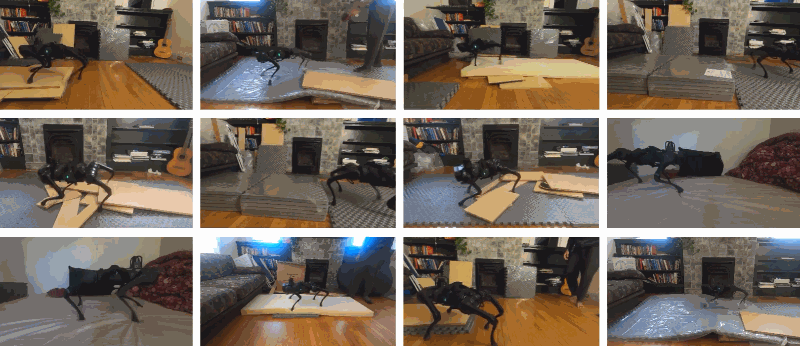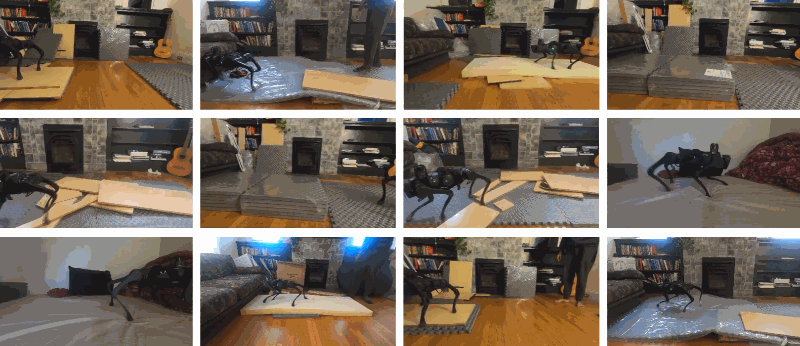
Image Credits: Berkeley AI Research, Facebook AI Research and CMU
After training in simulation, it passed handsomely in the real world, as the press release describes it:
The robot was able to walk over sand, mud, footpaths, tall grass and a lot of dirt in all our tests without failing once. In 70% of the tests, the robot successfully walked down a flight of stairs along a walking path. He successfully navigated a cement pile and a pile of pebbles in 80% of the trials, despite never seeing the unstable or sinking ground, obstructive vegetation or stairs during training. It also maintained its height with a high success rate when moving with a 12kg payload that was 100% of its body weight.
You can see examples of many of these situations in videos here or (very briefly) in the gif above.
Malik winked at .’s investigation NYU Professor Karen Adolph, whose work has shown how flexible and free the human process of learning to walk is. The team’s instinct was that if you want a robot that can handle any situation, it should learn to adapt from the start and not have to choose over a variety of modes.
Just as you can’t build a smarter computer vision system by exhaustively labeling and documenting every object and interaction (there will always be more), you can’t prepare a robot for a diverse and complex physical world with 10, 100, even thousands of special parameters for walking on gravel, mud, rubble, wet wood, etc. You may not even want to specify anything at all other than the general idea of forward motion.
“We’re not programming the idea that it has legs, or anything about the morphology of the robot,” Kumar said.
This means that the foundation of the system, not the fully trained system, which eventually molded itself into quadrupedal gaits, could potentially be applied not only to robots with different legs, but also to entirely different domains of AI and robotics.
“A robot’s legs resemble the fingers of a hand; the way legs interact with environments, fingers interact with objects,” noted co-author Deepak Pathak of Carnegie Mellon University. “The basic idea can be applied to any robot.”
Even further, Malik suggested, linking basic and adaptive algorithms could work for other intelligent systems. Smart homes and municipal systems usually rely on pre-existing policies, but what if they adapt right away instead?
For now, the team simply presents their initial findings in a paper on the Robotics: Science and Systems conference and recognize that much further research remains to be done. For example, building an internal library of the makeshift gaits as a kind of “mid-term” memory, or using vision to predict the need to initiate a new mode of locomotion. But the RMA approach appears to be a promising new approach to an enduring challenge in robotics.
|
Sources 2/ https://techcrunch.com/2021/07/09/stumble-proof-robot-adapts-to-challenging-terrain-in-real-time/ The mention sources can contact us to remove/changing this article |
[ad_2]